Friday, March 16, 2012

Tachyon III is in the Water!

After months of planing, design, fabrication, and testing, Tachyon III finally entered the water last Tuesday, March 13th.  We've been astounded at the increase in maneuverability and speed in this year's bot, and we're excited for the next few weeks of practicing.  Today, we began that process, putting a 5 hour run on Tachyon during an 11 hour meeting.  Over the next few days, Sam and I will be testing and fine tuning Tachyon for our first practice rounds.  Please stay tuned for more videos, photos, and posts as we get closer to regionals!


-Michael Ikegami

Tuesday, March 6, 2012

Update: 3/6/2011

With the regional competition approaching in April, Team Tachyon is only a few days away from having a competition-ready robot.  Over the past few weeks, Kieran has been designing and manufacturing a gripper that is ready for mounting on our frame, and Michael and Sam have been finishing and troubleshooting the control and waterproofing systems.  Our control system is now fully functional and installed onto our frame, and  all that we need to get this robot moving is to install our propellers.

Below are some videos we took of our control system in action.  The first shows our X axis and Z axis motors functioning simultaneously (and Sam consequently complaining about the sound).  The second, I think, is more exciting; it shows each motor on the X axis being controlled individually--a new feature this year in our control system.  Thanks for following us this year, and please stay in tune for more videos, pictures, and posts when we get our bot in the water in the next few weeks.

-Michael Ikegami and Kieran Wilson


Thursday, February 16, 2012

Getting there...

Everything is starting to come together;  the electrical systems were finished a few weeks ago, the frame was done shortly thereafter.  The waterproofing is just about done as well, and we should be able to pull everything together with in the next week or so.  Last year's frame is on the left; the longer, slightly narrower frame on the right is the basis of Tachyon III.
-Kieran Wilson

Saturday, January 21, 2012

An update: January 21, 2012

Over the past few weeks, Tachyon robotics has been working hard to complete our ROV for the upcoming MATE regional competition in April.  Meeting 2-4 times a week, we've completed almost every system on the robot and designed ideas for sensors, samplers, and tools to complete the mission tasks provided to us last December.  As of today, the main electrical system (excluding sensor bays, which are still in the prototyping phase) is ready to control our ROV, "Tachyon Mk. III."  Over the past few weeks, my job has been that of debugging and troubleshooting the three circuit boards that translate the signal put out from our microcontroller into movement for our motors.  This process has taken a lot of soldering, desoldering, fabricating and redesigning, but I am incredibly happy with our result.

In a meeting today, I was able to troubleshoot a bug in our circuitry that had caused some minor problems (such as a time limit on our runs due to excess power dissipation by our transistors) that we faced last year using a new tool we were able to purchase with money I had saved up: an oscilloscope.  Apart from giving me the opportunity to nerdily plot parametric equations in x-y mode, this new oscilloscope allows us to see the waveforms that potentiate our motors on a scale perfect for troubleshooting and optimizing.  Today I was able to use our O-scope to optimize both the frequency of our pulse with modulation and the values of certain pulldown resistors to increase the efficiency and maneuverability of this year's ROV.  Below is a picture taken from that process which shows two different waveforms on our oscilloscope's CRT.  The upper waveform was taken before I adjusted the values, and the bottom is taken at the end of today's meeting. Note that the lower wave is far more square than the upper.  This change will ensure that each movement our pilot makes on the joystick will correspond directly to a change in speed of the ROV.  In short, instead of not being able to throttle below 40% before the motors stop turning, as was the case last year, our pilot will be able to have more potentiation between full forward and full stop speeds (from 0% to 1.1% to 100%) on this year's ROV, which will shorten our mission time and lengthen the life of our components.

-Michael Ikegami   


Tuesday, December 13, 2011

Mission Specifications for the 2012 MATE ROV Competition

Mission specifications for the 2012 MATE ROV competition have been posted online by the Marine Advanced Technology Education Center!  Tachyon Robotics will be working over this weekend to determine how to overcome the challenges associated with this year's mission specifications.  Stay tuned for more details as we work to create possible solutions to the tasks presented in the link below.

http://www.materover.org/rov_competition_files/2012/2012_COMPETITION_MANUAL_FINAL.pdf

-Michael Ikegami

Saturday, October 29, 2011

The ROV to beat.


Above are some photos and a video of last year's ROV in action. This was the first year we incorporated semiconductor technology into the design of our control system and the difference was astounding! The maneuverability of last year's ROV allowed us to perform practice rounds in record breaking time. This year, we want to make our ROV even more maneuverable. Not only are we working to optimize the PWM frequency (which allows us to speed up and slow down the ROV in a manner more compatible with our motors and transistors), but we're also completing a control system that gives us a seamless transition between moving and turning, increasing our maneuverability, and hopefully, decreasing our mission time.

-Michael Ikegami

Monday, October 17, 2011

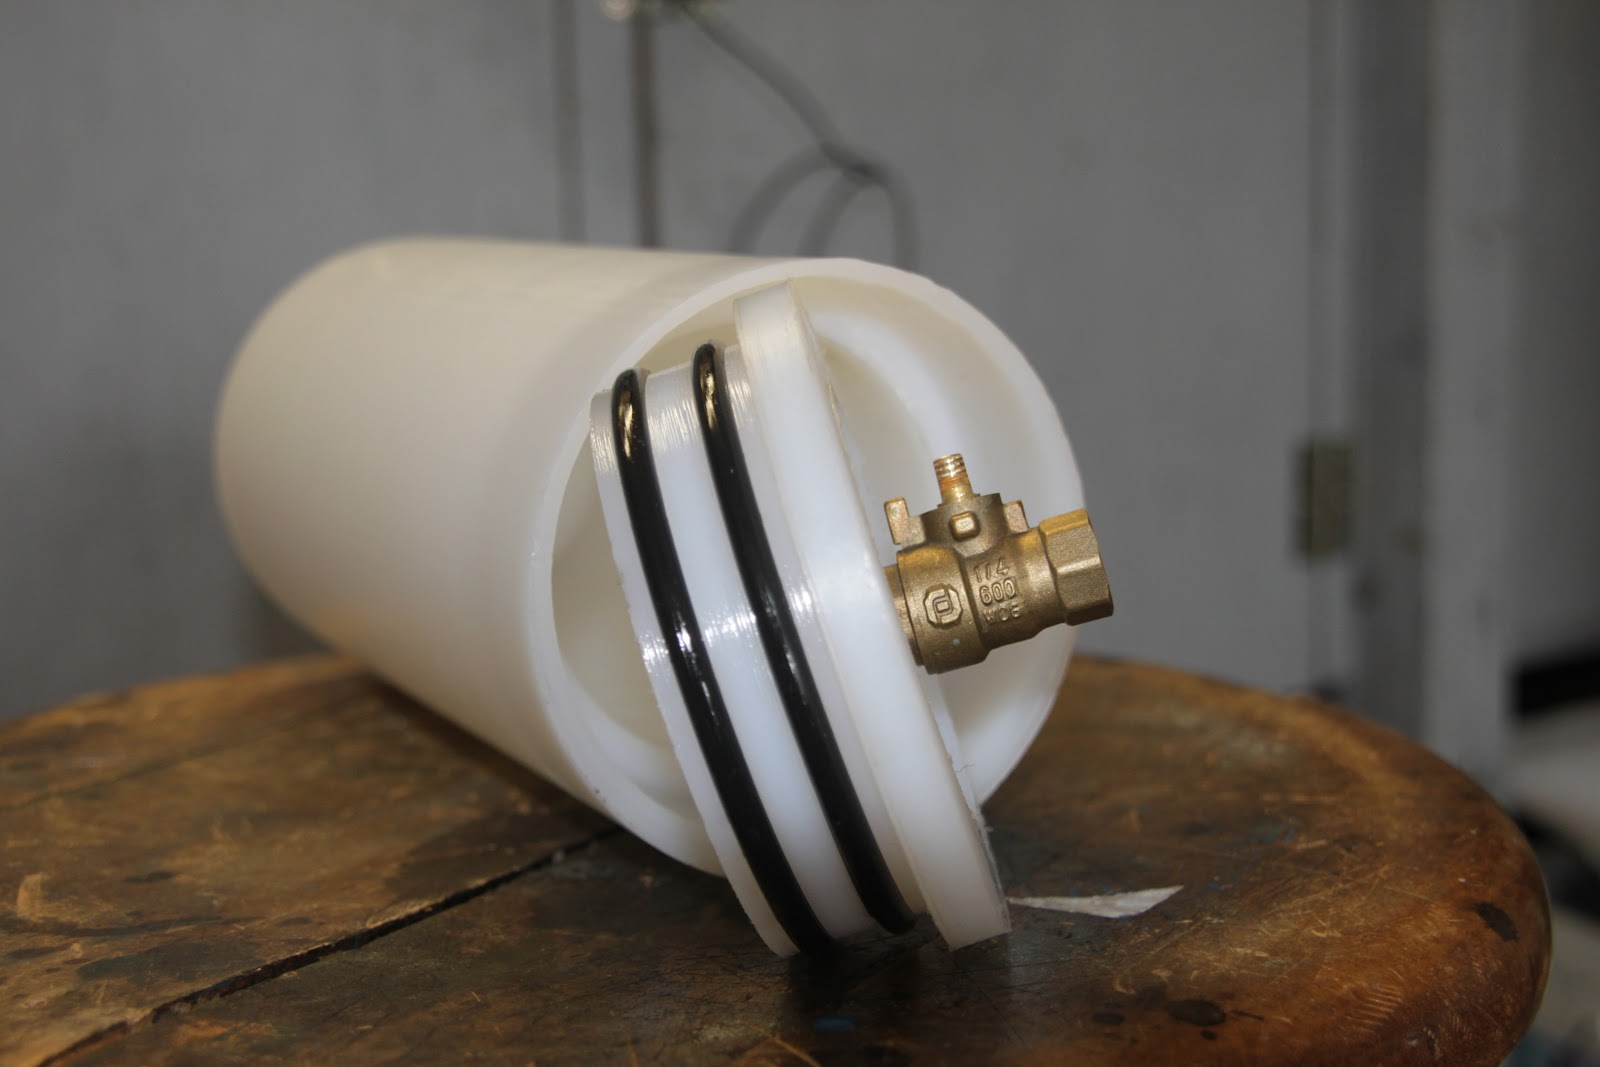
Pressure housing


The pressure housing has been machined out of UHMWPE, with the generous assistance of Dr Stuart Lilie. Without the time and equipment of Dr. Lilie, this pressure housing would have been nearly impossible to produce. Thanks to him, we have been able to produce a beautiful pressure housing, which should keep our electronics nice and dry.

-Kieran Wilson